Which sensors do I choose for the student robot: distance, inclination, orientation and position of the axis?
Distance, inclination, orientation and as axes are different measurements. Select the appropriate sensor for each sensor and check how to use the data in robot control.
What to check out
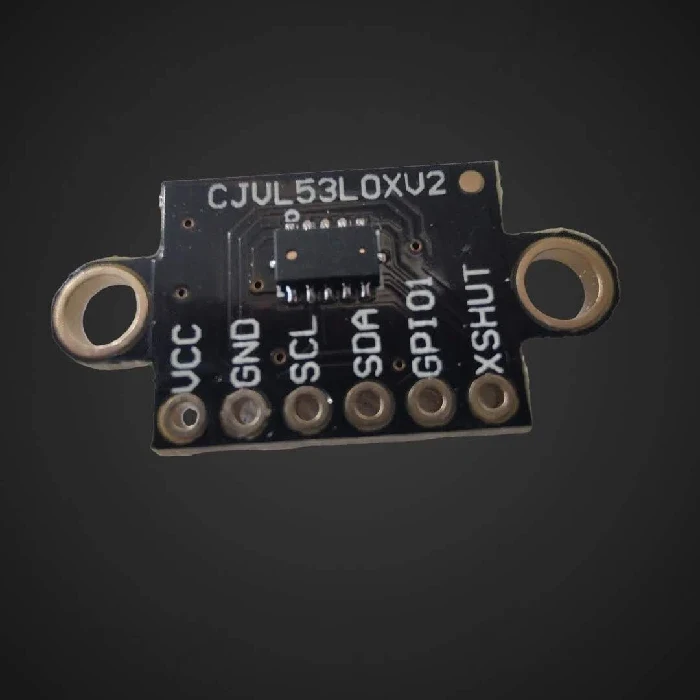
- Check the ToF-sensor for distance, its field of vision, target area and the effect of ambient light.
- Accelerator and gyroscope enable the assessment of movement and inclination; MPU6050 alone does not have a magnetometer for the absolute direction.
- For sensor fusion modules, check the reference system, calibration and magnetic interference.
- The magnetic encoder, such as AS5600, is interesting for the angle of the axis with a properly selected and installed magnet.
A Practical Example
The robot can use ToF to check the obstacle, IMU to monitor the inclination and encoder the position of the mechanism. None of these measurements alone provide the exact location of the entire robot in the space.
Common error
Do not combine data from different coordinate systems without conversion. A magnet with an engine or steel structure can affect magnetic measurements.
For further reading
- STMcroelectronics: VL53L0X sensor documentation (English). Example of official specifications and software resources to measure the distance on the robot.
Compatibility check products
Select products according to the above criteria; the list is not a confirmation that they are all interchangeable.
Published:
21.10.2026